 English
 中文简体
Two layouts that distribute complexity differently
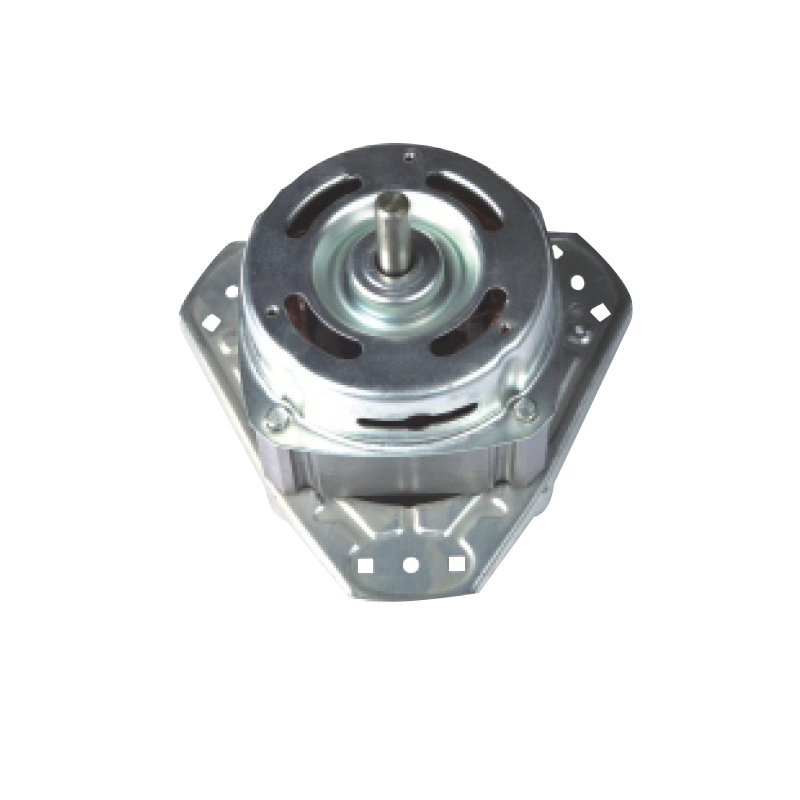
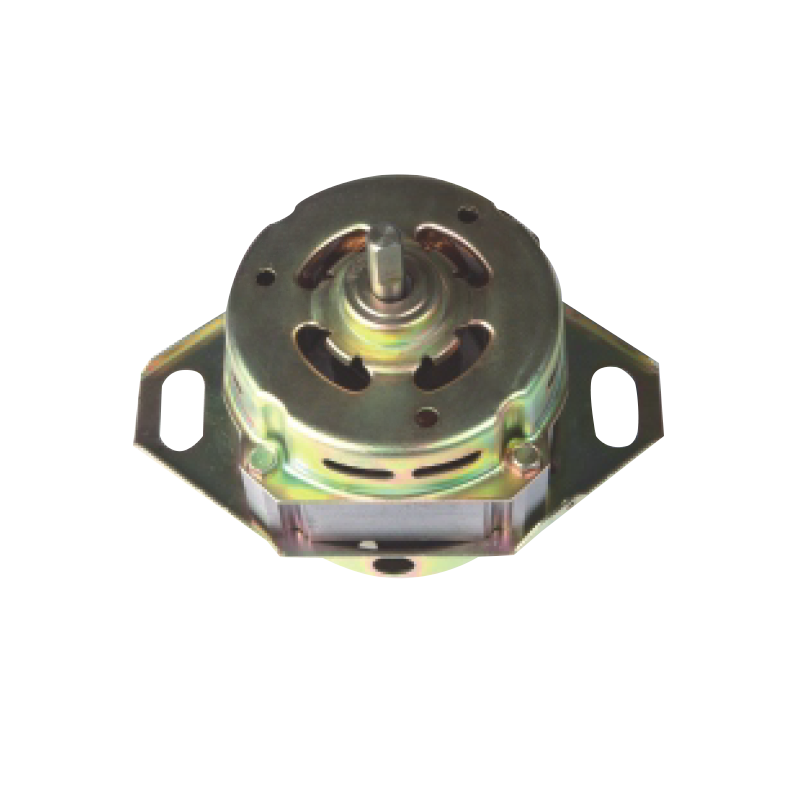
In a belt-drive washing machine, the motor is mounted away from the drum axis and transfers torque through pulleys and a belt. In a direct-drive design, the motor rotor is coupled to the drum axis, often with a large-diameter motor integrated around the rear bearing region. Neither architecture eliminates engineering compromises. Belt drive introduces a transmission and its associated tension, alignment and maintenance. Direct drive removes the belt but concentrates motor, bearing, sealing and structural requirements near the drum.
Comparisons that declare direct drive “more efficient” or belt drive “cheaper” without specifying the machine and operating point are incomplete. The correct boundary includes the motor, transmission, support bearings, suspension, cabinet packaging, assembly labor and service strategy. The better choice depends on speed range, torque, target acoustic performance, manufacturing volume and the desired repair model.
Speed ratio determines motor geometry
A belt system can use a relatively high-speed motor and reduce speed at the drum. With a 40 mm motor pulley and a 160 mm drum pulley, the nominal ratio is 4:1. At 1,000 rpm drum speed, motor speed is about 4,000 rpm before slip. The motor can deliver lower torque at higher speed for the same mechanical power. A direct-drive motor turns at drum speed, so it must provide the required drum torque directly, commonly motivating a larger rotor diameter or different electromagnetic design.
Mechanical power still follows P = Tω. At a drum torque of 2 N·m and 1,000 rpm, output is about 209 W. If a belt transmits 92% of motor mechanical power under a particular operating condition, the motor must produce about 227 W to deliver that drum output. The 92% value is an assumed example; real efficiency depends on belt construction, tension, pulley size, alignment and load. Direct drive removes that particular transmission loss but can have different motor and controller losses.
Bearing loads and structural integration
A belt produces radial loading on the motor and drum shafts. Belt tension must be high enough to transmit torque without unacceptable slip, but excess tension increases bearing load and may accelerate wear. Misaligned pulleys create edge wear and vibration. Engineers should verify pulley coplanarity, belt tension range and bearing capacity across assembly tolerances. A belt system also needs physical clearance for the moving belt and a safe guarding strategy.
Direct drive removes belt tension but makes rotor alignment, drum-bearing geometry and mounting stiffness particularly important. A large-diameter rotor can be sensitive to eccentricity and air-gap variation. Drum-bearing movement may influence electromagnetic clearance and acoustic behavior. Service access can also be different: a motor integrated with the rear tub may be more difficult to replace than an external belt-driven unit. The architecture changes where mechanical risk is concentrated rather than making it disappear.
Energy efficiency is a map, not one percentage
Consider two hypothetical systems at a mechanical drum output of 200 W. A belt-drive motor operating at 84% efficiency with a 92% efficient belt has an overall mechanical-to-electrical efficiency of 0.84 × 0.92 = 77.3%, requiring about 259 W input. A direct-drive motor and controller operating together at 82% efficiency requires about 244 W. Under these specific assumptions, direct drive saves about 15 W at that operating point. If the direct-drive system were less efficient at a different low-speed condition, the ranking could reverse.
Cycle-level measurement should cover agitation, acceleration, spin and idle intervals. Energy savings claimed from removing a belt should not be extrapolated to an entire wash program without measuring the complete system. For appliance labeling, the applicable product test method and national market rules take precedence over isolated motor efficiency figures.
| System attribute | Belt drive | Direct drive |
|---|---|---|
| Speed matching | Pulley ratio provides flexibility | Motor follows drum speed |
| Extra transmission loss | Belt and pulley losses | No belt loss |
| Mechanical sensitivity | Tension, alignment, belt wear | Air gap, mounting and bearing alignment |
| Service approach | Belt/motor may be replaced separately | Integration can complicate access |
| Packaging | Motor offset from drum axis | Motor concentrated on drum axis |
Noise and vibration take different paths
A belt drive can produce belt-slip noise, pulley eccentricity excitation and structure-borne vibration through the motor mounts. At the same time, the belt and flexible mounting can provide some mechanical isolation between motor and tub. A direct-drive arrangement avoids belt noise but transmits electromagnetic torque ripple and rotor-related vibration closer to the drum structure. Neither configuration guarantees a quieter washer.
Acoustic evaluation should separate wash agitation, ramp-up and steady spin. Use consistent microphone positions, background-noise conditions and textile loads. Frequency analysis can distinguish motor electromagnetic tones from bearing defects, belt-related modulation and cabinet resonances. A single dB(A) number is useful for a headline comparison but insufficient for locating the design cause of a tonal complaint.
Assembly economics and tolerance stack-up
Belt drive adds belt fitting, tension verification, pulley installation and alignment checks to the production line. Direct drive may eliminate those steps but require tighter rotor positioning, magnet handling, air-gap verification and different end-of-line checks. The net assembly benefit depends on tooling, takt time, automation and reject rates. A design that saves three assembly operations can still be more expensive if it needs precision fixtures or creates difficult rework.
For a simple hypothetical comparison, suppose belt-related assembly tasks require 90 seconds per machine and direct-drive-specific checks require 50 seconds. The apparent saving is 40 seconds. At 100,000 units per year, that equals about 1,111 labor-hours before allowing for line balance, rework and equipment uptime. The economic value depends on local labor cost and whether the removed time actually increases line throughput. This is why takt-time studies should accompany component quotations.
Failure analysis and service cost
Belt slip can show up as reduced drum speed, heat, dust or squeal, particularly when tension or pulley condition deteriorates. Bearing wear may appear as broadband noise, vibration or radial play in either architecture. Direct-drive problems can involve rotor position sensing, power electronics, mounting movement or magnetic clearance. Technicians need diagnostic procedures that distinguish electrical faults from drum-bearing and suspension faults.
Warranty analysis should use field failure rates and replacement labor, not only the purchase price of the motor. A low-cost belt is inexpensive to replace but still creates a service event. A highly integrated drive may reduce some wear components yet make a rare repair more expensive. Expected lifecycle cost is the probability-weighted sum of those events, plus energy and manufacturing costs.
Choose architecture from the washer platform backward
For OEMs, define required drum torque, spin speed, package depth, cabinet vibration target, assembly strategy and repair philosophy before selecting the motor architecture. A belt-drive platform may be attractive where component flexibility, simple service and established tooling dominate. Direct drive may suit products that prioritize integrated control, reduced transmission parts and a compact axial layout, provided the bearing structure and electronics are engineered accordingly.
The decisive comparison is a controlled prototype evaluation of complete appliances: energy over the same cycle, vibration under the same unbalanced load, assembly time on the intended line and expected service cost. A belt is neither automatically obsolete nor automatically inferior; direct drive is neither automatically silent nor automatically more efficient at every point. The best design is the one whose system-level tradeoffs fit the target washer and its production economics.